Profile
About Me
I am a robotics researcher specializing in perception, planning, and autonomous systems. My research focuses on multi-agent embodied navigation, semantic spatial perception, and the integration of classical robotics algorithms with foundation models for semantically aware autonomy.
My work sits between engineering and mathematics: SLAM, localization, control, mapping, task allocation, and vision-language reasoning. I like building systems that move from equations and simulation into physical robots, field tests, and reproducible research artifacts.
Research & Interests
My work sits on one question: how to get the semantic reasoning of foundation models without giving up the reliability classical robotics already provides. Classical methods are not obsolete. The interesting problem is knowing where a learned model earns its place and where a particle filter still wins.
Track record
Experience
Professional experience in robotics research and engineering roles.
Research Technician
Skolkovo Institute of Science and Technology (July 2026 - present)
Research Technician working on Skyliner, vision-language navigation for GPS-denied UAV flight. Co-developing navigation that combines route guidance with verified visual landmarks and falls back to route control when visual evidence degrades. Demonstrated closed-loop transitions between route and visual control.
Graduate Student Researcher
Intelligent Space Robotics Lab (Nov 2024 - Jun 2026)
Led the research, implementation and evaluation of AnyGoal and GoalVLM for training-free cooperative navigation; developed decentralized semantic coordination for GoalSwarm. Contributed perception, human-pose processing, grounding, physical UAV integration and experiments to DroneVLA. Led Eurobot 2025 particle-filter localization using 2D LiDAR, IMU and wheel odometry, with approximately 2 cm positional error in field testing.
Robotics Software Engineer - Intern
Waybot Robotics (May - August 2025)
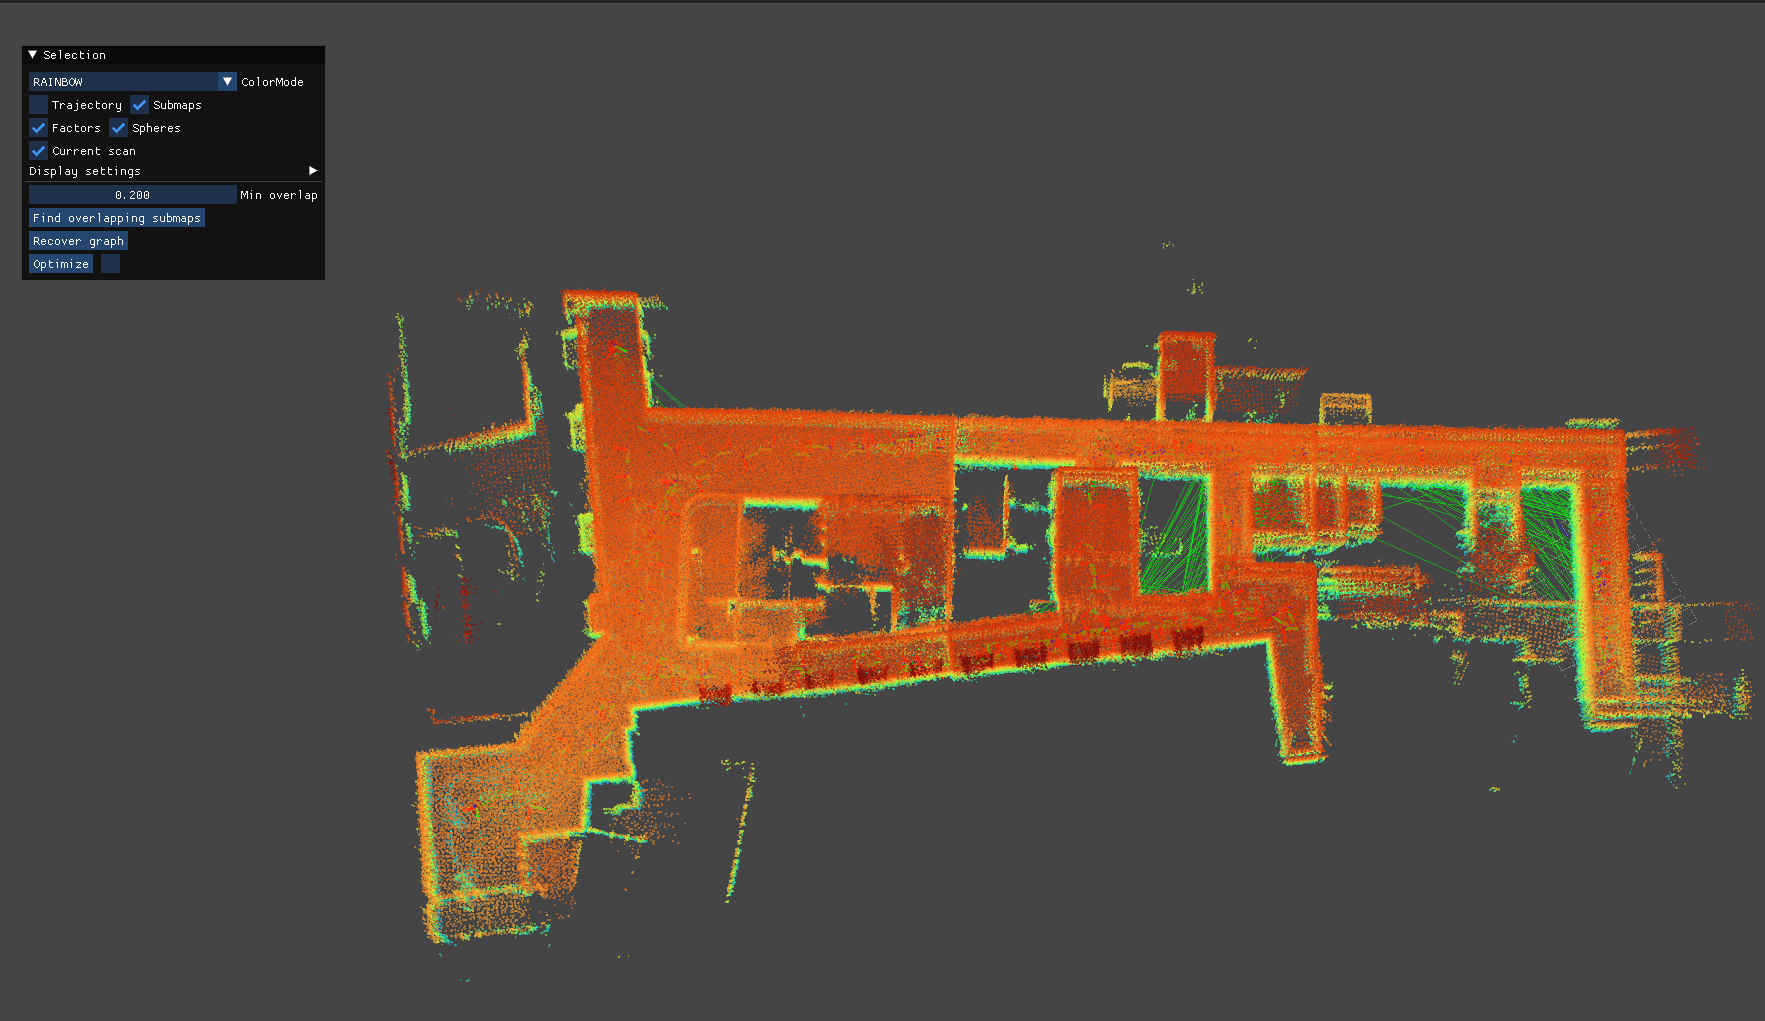
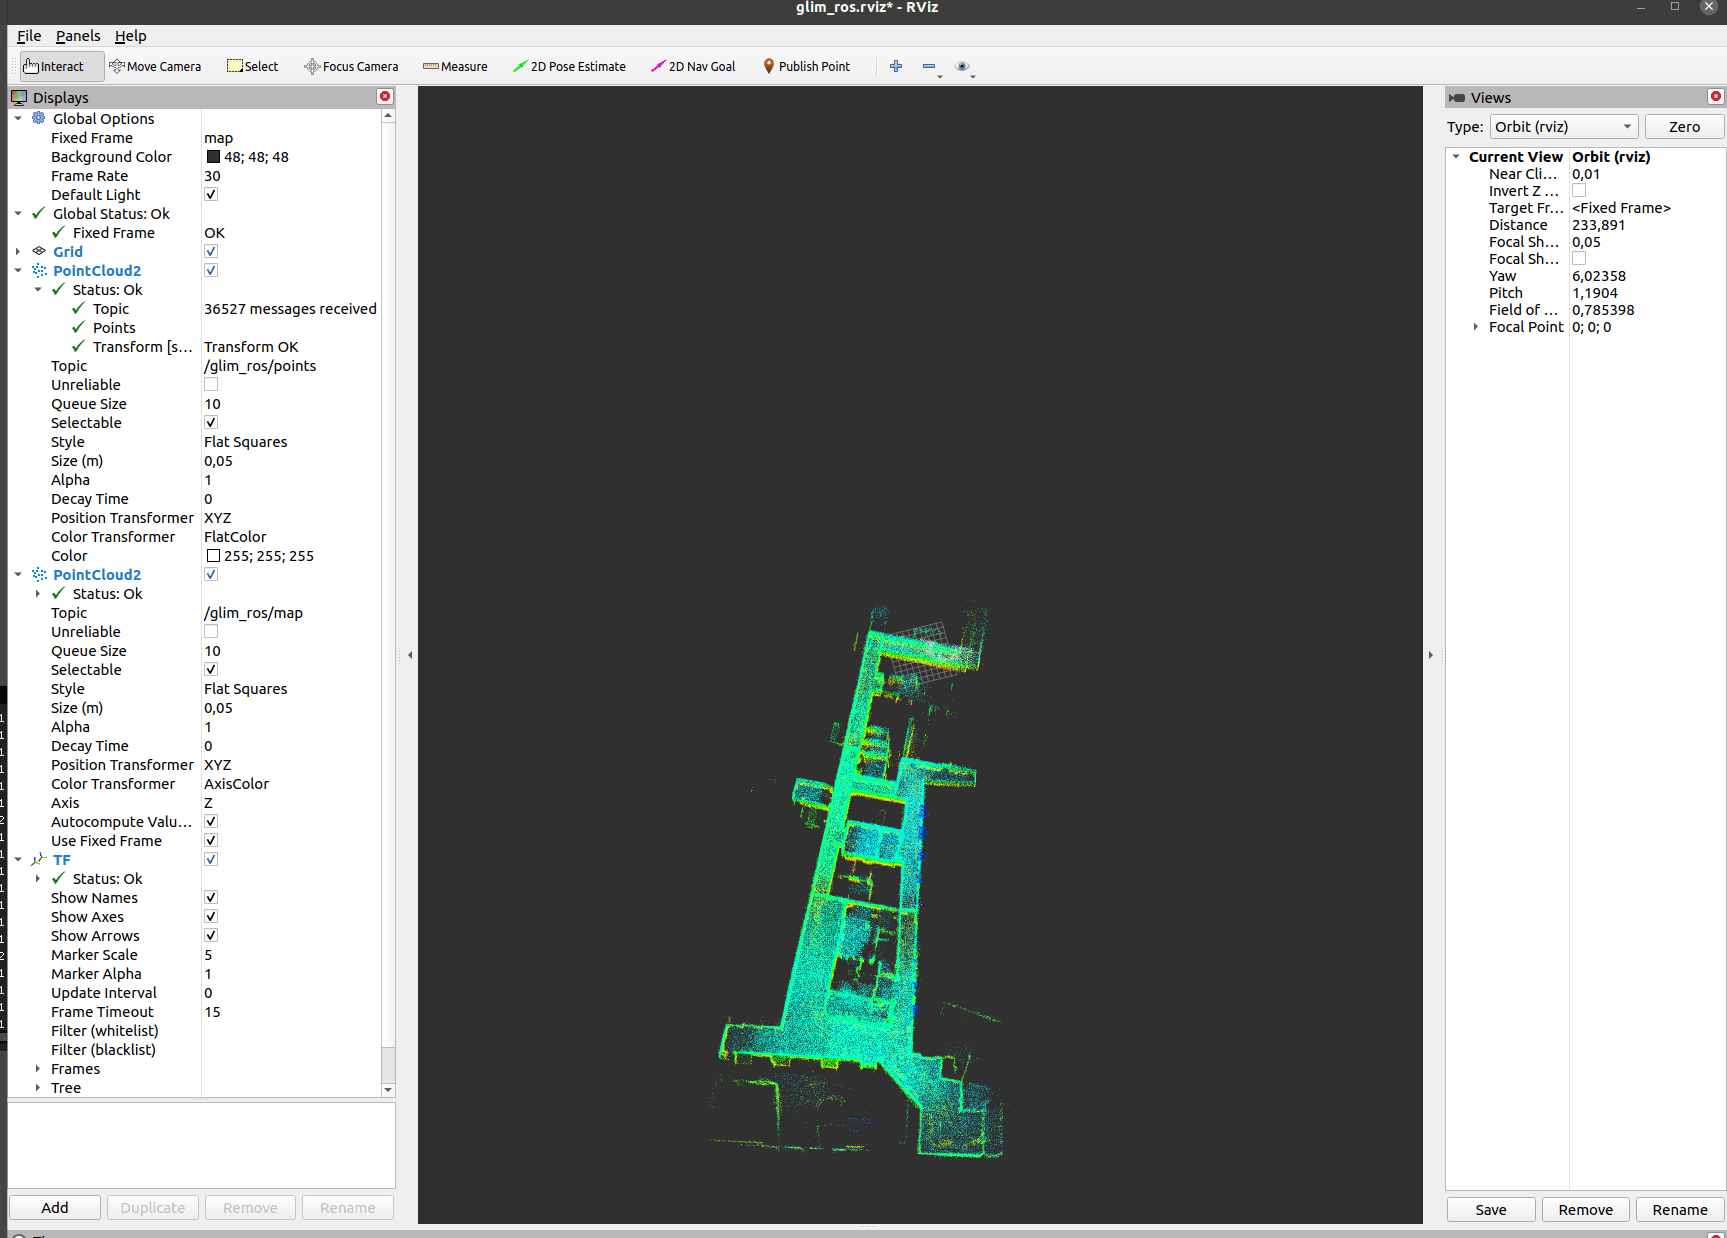
Implemented 3D-LiDAR based SLAM for ground-based professional cleaning robots. Reviewed and tested state-of-the-art SLAM methods (ICP, NDT, GICP, VGICP). Gained expertise in point cloud matching algorithms and real robot parameter optimization.
Intern Engineer
Autonomous Tech (June - July 2025)
Built a custom quadcopter from mechanical assembly and electronics through firmware, ArduPilot and ROS 2/MAVProxy integration. Implemented ultrasonic obstacle avoidance and tested sensor placement against propeller wash.
Intern Engineer
Mikom Servis (June - July 2023)
Designed, developed, and tested an autonomous ground robot. Implemented YOLO for road sign detection and Hector SLAM for 2D LiDAR-based mapping and localization in unknown environments.
Stack
Skills & Expertise
Technical expertise spanning the full robotics stack, from low-level hardware to high-level AI integration.
Robotics & Control
Computer Vision & Perception
Machine Learning & AI
Programming & Tools
Education
MSc Engineering Systems (Robotics)
Center for Digital Engineering
Thesis: VLM-driven multi-modal lifelong navigation for swarm robotic systems.
Bachelor of Mechatronics and Robotics
Department of Robotics and Mechatronics
Research Focus Areas
Recognition
Awards & Scholarships
Scholarship for Development: Top Paper
Skolkovo Institute of Science and Technology
Champions: Eurobot Open, Russia
Eurobot Russia
Audience Award: Triple Point Startup Competition
Skolkovo Institute of Science and Technology
Scholarship for Development: Champions
Skolkovo Institute of Science and Technology
Full Master's Degree Scholarship
Skolkovo Institute of Science and Technology
2nd Place: Russian Language Olympiad (All-Russian)
Southern Federal University
Full Undergraduate Scholarship (BEA)
Nigerian Federal Scholarship Board
Open to Opportunities
What I'm Looking For
PhD Opportunities
Seeking PhD positions in robotics, autonomous systems, or computer vision research, particularly in areas involving vision-language models and robot perception.
Research & Industry Roles
Open to research engineer positions, robotics internships, and collaboration opportunities in autonomous systems and AI-driven robotics.